


Tuning the Position Loop
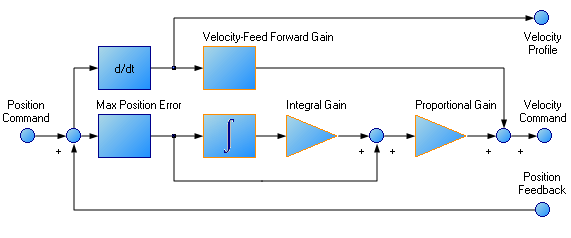
The position loop is a second loop that builds upon a correctly tuned velocity loop to provide accurate control over position. The position loop is a simple element that consists of a PI loop. It is simplest to tune the P and I terms in the velocity loop and use only the P term in the position loop.
Referenced Parameters
| Parameter | Description | Drive Keyword |
|---|---|---|
|
PL.KI |
Positioon Loop Integral Gain |
|
|
PL.KP |
Position Loop Proportional Gain |
|
|
VL.KI |
Velocity Loop Integral Gain |
|
|
VL.KP |
Velocity Loop Proportional Gain |
|
|
VL.KVFF |
Velocity Loop Feed Forward |
At most, use only three non-zero P and I terms from both the velocity loop and the position loop. One combination would be VL.KP, VL.KI and PL.KP. Another valid combination would be VL.KP, PL.KP and PL.KI. The VL.KP, VL.KI and PL.KP combination is shown below.
Procedure for tuning position loop:
- Set VL.KVFF to 1
- Increase PL.KP until either:
- You see 25% overshoot, or
- You see > 3 overshoots, or
- You hear objectionable noises from the system.
- When you reach one of the limits above, decrease PL.KP to the value where there were no objectionable noises or overshoot.