Motor Thermal Protection Algorithm
Parameters
The following parameters are used for the motor thermal protection algorithm:
- Motor peak and continuous currents in Arms.
- Motor coil thermal constant in mHz.
- Warning threshold in Arms. The AKD2G generates a warning in case AXIS#.IL.MIFOLD drops below this warning threshold.
- Fault threshold in Arms. The AKD2G generates a fault in case AXIS#.IL.MIFOLD drops below this fault threshold.
If AXIS#.MOTOR.ICONT and AXIS#.MOTOR.IPEAK have not been automatically configured, set them to the continuous and peak current ratings of the AXIS#.MOTOR, respectively.
If AXIS#.MOTOR.CTF0 has not been automatically configured, set it to the coil thermal constant of AXIS#.MOTOR in mHz.
Then configure the warning or fault thresholds using AXIS#.IL.FOLDWTHRESH or AXIS#.IL.FOLDFTHRESHU respectively. Note that:
-
AXIS#.IL.FOLDWTHRESH must be set above AXIS#.IL.FOLDFTHRESH, otherwise it is ignored.
-
AXIS#.IL.FOLDWTHRESH and AXIS#.IL.FOLDFTHRESH set the warning and fault thresholds for BOTH motor and drive thermal protection algorithms.
-
Both AXIS#.IL.FOLDWTHRESH and AXIS#.IL.FOLDFTHRESH must be below the peak current rating of both motor and drive.
Functional Description of the Motor Thermal Protection Algorithm
The motor thermal protection algorithm estimates the coil temperature of the motor and limits the maximum applicable current to keep the coil temperature below 150°C. The maximum applicable current set by motor protection algorithm is AXIS#.IL.MIFOLD. This maximum limit is set based on the current value and previous values of the current command.
For example, if the current command has been zero for a while, AXIS#.IL.MIFOLD will be equal to the AXIS#.MOTOR.IPEAK, which means that the maximum applicable current is the motor peak current.
If the current command then goes to AXIS#.MOTOR.IPEAK, AXIS#.IL.MIFOLD starts dropping below AXIS#.MOTOR.IPEAK after some time to ensure coil temperature of the motor is in the safe region.
Eventually, AXIS#.IL.MIFOLD will decrease to a level close to AXIS#.MOTOR.ICONT after a long time (depending on the coil thermal time constant of the motor).
The following figures depict typical AXIS#.IL.CMD and AXIS#.IL.MIFOLD waveforms as well as estimated coil temperature for a motor with the following parameters as an example:
-
AXIS#.MOTOR.IPEAK = 20 Arms
-
AXIS#.MOTOR.ICONT = 5 Arms
-
AXIS#.MOTOR.CTF0 = 1/(2×π×40 sec) = 4 mHz
-
Ambient temperature = 25°C
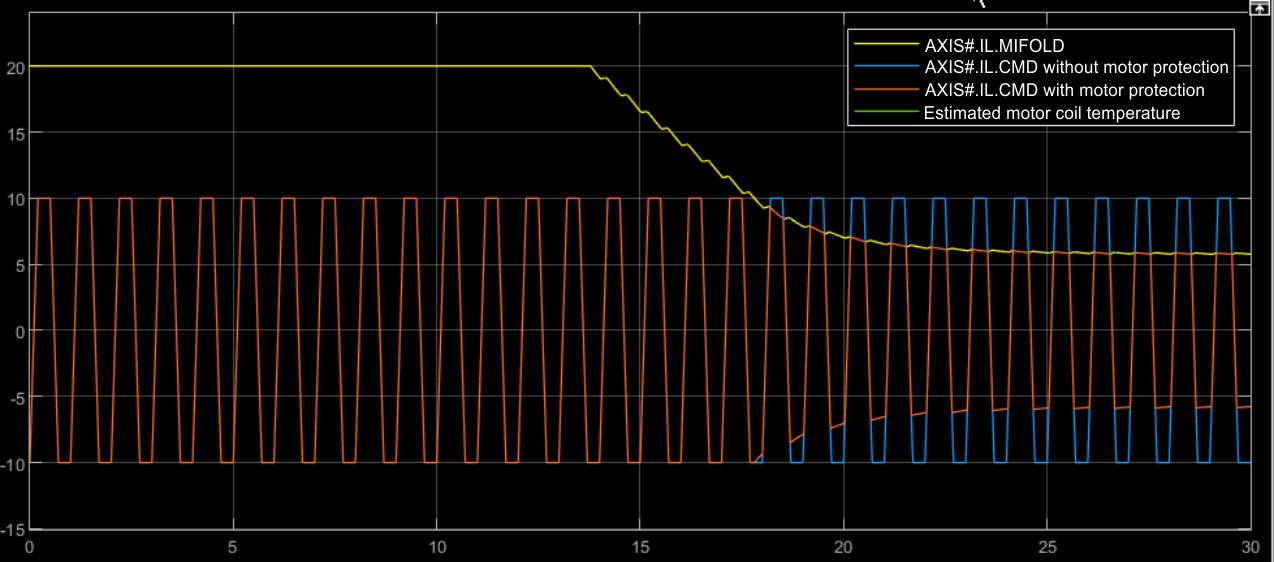
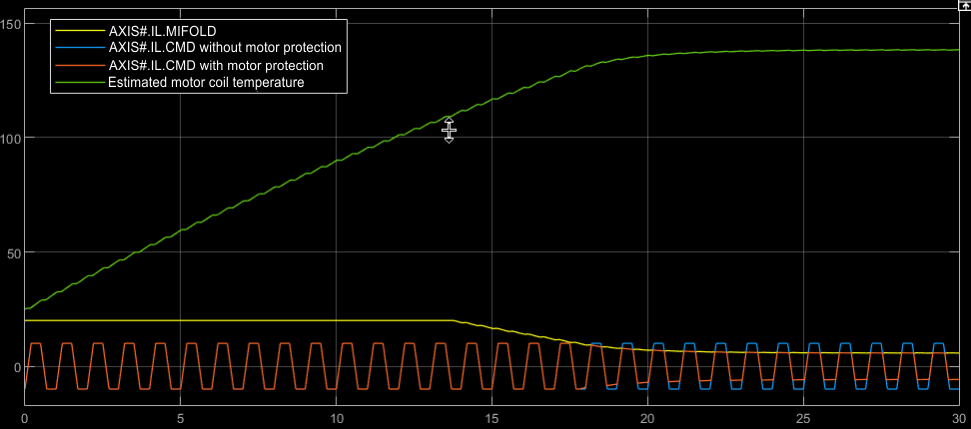
As can be seen in these figures, as the estimated coil temperature approaches the maximum rated temperature (150°C), the motor foldback algorithm starts limiting the maximum current command (AXIS#.IL.CMD) to prevent the coil temperature from exceeding 150°C. The current command waveform shown here can be the result of a certain motion profile.


