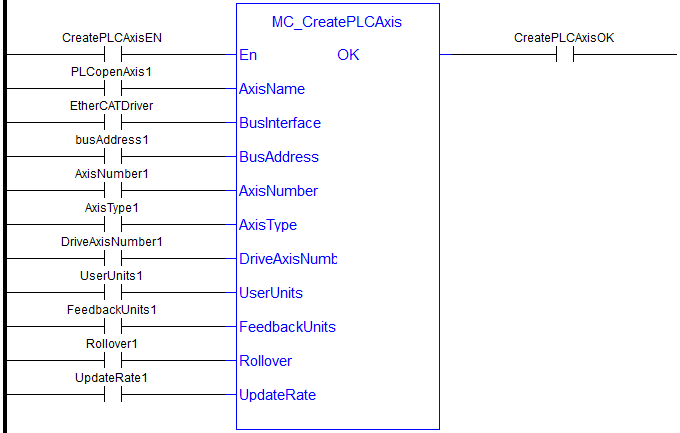
Function
 A function calculates a result according to the current value of its inputs. A function has no internal data and is not linked to declared instances. - creates a PLCopen A vendor -and product- independent worldwide association active in Industrial Control and aiming at standardizing PLC file formats based on XML Axis.
A call to this function is automatically generated when the application is compiled, based on the data entered in the PLCopen Axis Data dialog.
-
-
MC_CreateAxis must be called between MLMotionInit and MLMotionStart.
Arguments
See Function Blocks - General Rules for more information about how inputs and outputs work.
Input
| En | Description | Requests to create a PLCopen axis | |||||||||
| Data type | BOOL | ||||||||||
| Range | 0, 1 | ||||||||||
| Unit | N/A | ||||||||||
| Default |
No default |
||||||||||
| AxisName | Description | Axis name | |||||||||
| Data type | STRING | ||||||||||
| Range | — | ||||||||||
| Unit | N/A | ||||||||||
| Default | — | ||||||||||
| BusInterface | Description | Bus interface identifier: “EtherCATDriver” = EtherCAT ***EtherCAT is an open, high-performance Ethernet-based fieldbus system. The development goal of EtherCAT was to apply Ethernet to automation applications which require short data update times (also called cycle times) with low communication jitter (for synchronization purposes) and low hardware costs interface“MSBusDriver” = KAS Simulator interface |
|||||||||
| Data type | STRING | ||||||||||
| Range | — | ||||||||||
| Unit | N/A | ||||||||||
| Default | — | ||||||||||
| BusAddress | Description | Address of the drive on the bus | |||||||||
| Data type | DINT | ||||||||||
| Range | bus dependent | ||||||||||
| Unit | N/A | ||||||||||
| Default | — | ||||||||||
| AxisNumber | Description | Axis number | |||||||||
| Data type | UINT | ||||||||||
| Range | [1,256] | ||||||||||
| Unit | N/A | ||||||||||
| Default | — | ||||||||||
| AxisType | Description |
|
|||||||||
| Data Type | USINT | ||||||||||
| Range | [0,1] | ||||||||||
| Unit | N/A | ||||||||||
| Default | — | ||||||||||
| DriveAxisNumber | Description | This one-based number specifies the axis on the drive. For a single-axis drive this number should be 1. |
|||||||||
| Data type | UINT | ||||||||||
| Range | [1,256] | ||||||||||
| Unit | N/A | ||||||||||
| Default | — | ||||||||||
| UserUnits | Description | User unit portion of the user unit/feedback unit ratio | |||||||||
| Data type | DINT | ||||||||||
| Range | [1, 2147483647] | ||||||||||
| Unit | User unit | ||||||||||
| Default | — | ||||||||||
| FeedbackUnits | Description | Feedback unit portion of the user unit/feedback unit ratio | |||||||||
| Data type | DINT | ||||||||||
| Range | [1, 2147483647] | ||||||||||
| Unit | Feedback units | ||||||||||
| Default | — | ||||||||||
| Rollover | Description | Rollover position (0 = no rollover) | |||||||||
| Data type | LREAL | ||||||||||
| Range | [0, 4294967296] | ||||||||||
| Unit | User unit | ||||||||||
| Default | — | ||||||||||
| UpdateRate | Description | Servo update rate (0, 1, and 2 are reserved for future enhancements) 3 = 125 μsec 4 = 250 μsec 5 = 500 μsec 6 = 1 msec 7 = 2 msec 8 = 4 msec 9 = 8 msec |
|||||||||
| Data type | UINT | ||||||||||
| Range | [3,9] | ||||||||||
| Unit | N/A | ||||||||||
| Default | — |
Output
| OK | Description |
Indicates the axis has been created. See Function - General Rules for more information. |
| Data type | BOOL |
Example
Structured Text
(* MC_CreatePLCAxis ST
AxisName1 := 'PLCOpenAxis1';
BusName1 := 'EtherCATDriver';
BusAddress1 := 1001;
AxisNumber1 := 1;
AxisType1 := MC_AXIS_TYPE_SERVO_STEPPER;
DriveAxisNumber1 := 1;
UserUnits1 := 360;
FeedbackUnits1 := 1048576;
Rollover1 := 0;
UpdateRate1 := 3;
MC_CreateAxis(AxisName1, BusName1, BusAddress1, AxisNumber1, AxisType1, DriveAxisNumber1, UserUnits1, FeedbackUnits1, Rollover1, UpdateRate1);
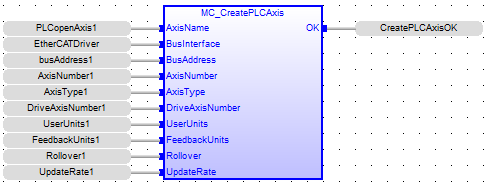
Function Block Diagram
Ladder Diagram